Loading...
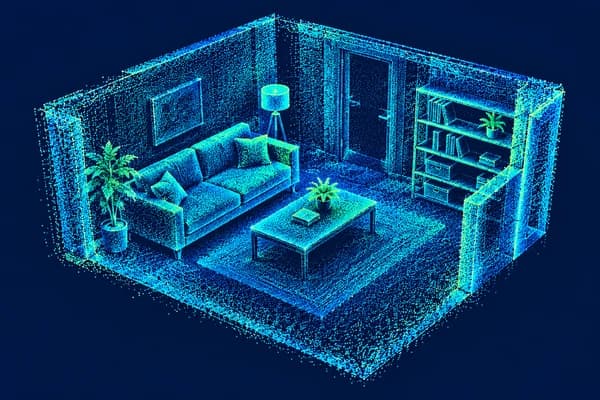
Paired synthetic (Isaac Sim) and physical twin real-world trajectories with parametric friction, lighting variation, texture randomization, and camera latency jitter.
Robot Platform & Actuation
Franka Research 3 with parallel jaw gripper
Sensor Payloads & Streams
Paired synthetic and physical RealSense D435i RGB-D, simulated tactile arrays, ground-truth physics states
Operating Environment
Simulated tabletop paired with physical twin robotics lab testbed
Data Formats & Containers
HDF5, WebDataset, Isaac Gym tensor dumps
grasp contact confirmed (mu=0.65)
Fz: 9.81 N
Tiered pricing for commercial enterprise foundation models or academic research labs.