Loading...
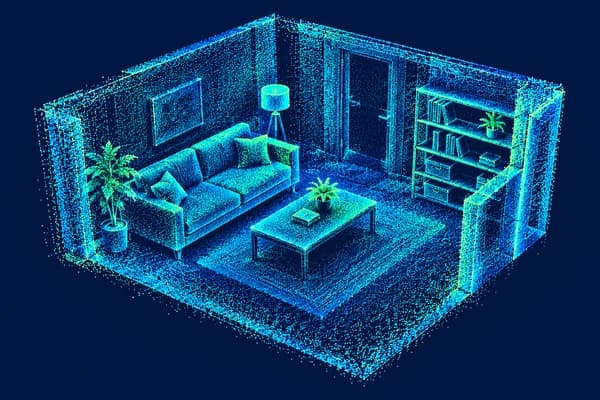
Domain-randomized simulation rollouts in Isaac Sim and MuJoCo engineered with varied lighting, dynamics, and friction for robust sim-to-real transfer.
Filter by kinematics, sensor modalities, and hardware embodiment. Inspect sample telemetry streams in real time.
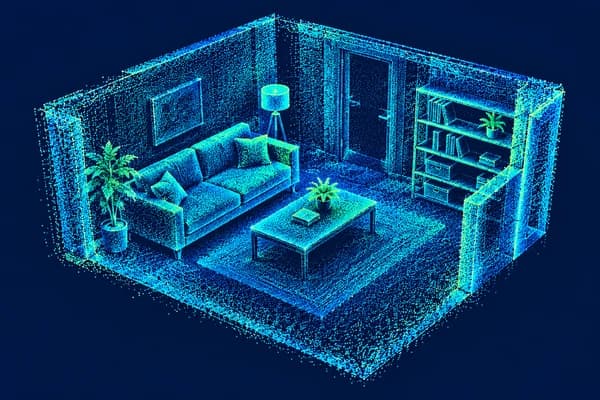
Paired synthetic (Isaac Sim) and physical twin real-world trajectories with parametric friction, lighting variation, texture randomization, and camera latency jitter.
We deploy targeted teleoperation rigs, custom sensor suites, and dedicated robot hardware for proprietary foundation model training.