Loading...
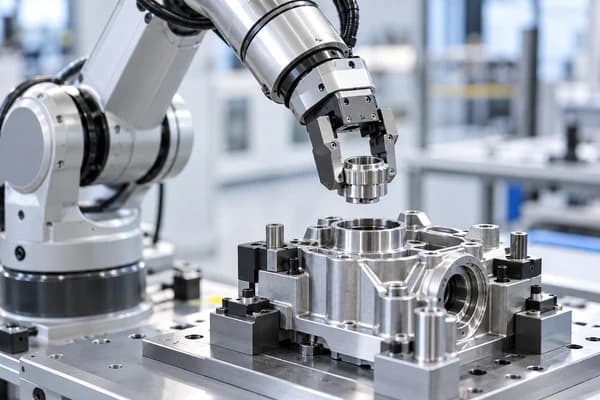
High-fidelity human teleoperation demonstrations captured via VR headsets, haptic controllers, and kinesthetic rigs for imitation learning.
Filter by kinematics, sensor modalities, and hardware embodiment. Inspect sample telemetry streams in real time.
High-precision peg-in-hole, cable routing, and electronic sub-assembly demonstrations captured via bilateral haptic masters with micro-Newton force feedback.
We deploy targeted teleoperation rigs, custom sensor suites, and dedicated robot hardware for proprietary foundation model training.