Loading...
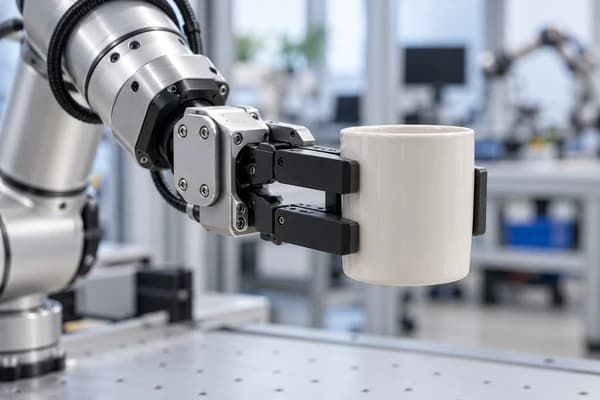
Curated dexterous manipulation, bimanual teleoperation, pick-and-place, and precision assembly datasets across structured and unstructured environments.
Filter by kinematics, sensor modalities, and hardware embodiment. Inspect sample telemetry streams in real time.
500 hours of synchronized bimanual teleoperation across 12 domestic and commercial kitchen environments, capturing articulated object interactions, cooking prep, and tool use.
We deploy targeted teleoperation rigs, custom sensor suites, and dedicated robot hardware for proprietary foundation model training.